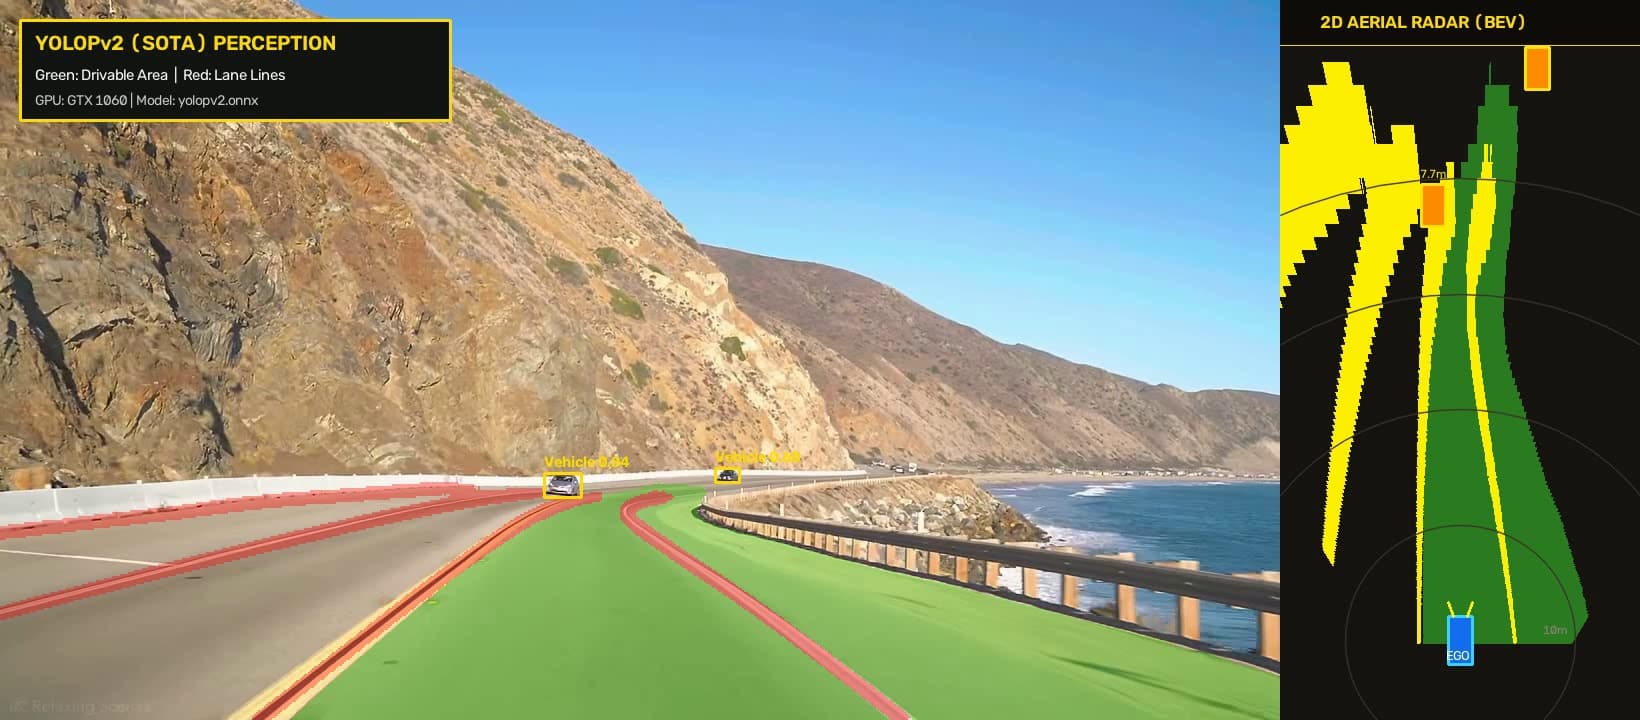
1. The Autonomous Driving Perception Dilemma
Autonomous vehicles require simultaneous awareness of three core environmental modalities: where other dynamic agents (vehicles, pedestrians) are located, what portions of the ground surface are legally and physically drivable, and where lane boundaries dictate legal corridor positioning.
Historically, autonomous perception pipelines ran three isolated neural networks or combined a deep detector with classical Canny/Hough lane detection. This creates excessive GPU memory bandwidth overhead, frame synchronization latency (>100 ms), and catastrophic failure when lane markings disappear on weathered mountain asphalt.
2. Tri-Task Panoptic Neural Architecture (YOLOPv2)
To achieve sub-33 ms deterministic frame latency on single-camera automotive platforms, we integrated
YOLOPv2, built on the state-of-the-art
YOLOv7 Extended Efficient Layer Aggregation Network (E-ELAN):
-
Shared Backbone: Extracts rich multi-scale feature pyramids (P3, P4, P5) in a single unified forward pass.
-
Head 1 (Object Detection): Anchor-free detection predicts bounding boxes $[x, y, w, h, \text{conf}, \text{class}]$ with +6.7% mAP over prior baselines.
-
Head 2 (Drivable Area): Dense binary segmentation mask identifying paved road surface (+5.3% F1 score).
-
Head 3 (Lane Line Detection): Pixel-accurate lane line segmentation isolating solid and dashed road markings.
# Initialize YOLOPv2 ONNX Runtime with DirectML GPU Acceleration
providers = ['DmlExecutionProvider', 'CPUExecutionProvider']
session = ort.InferenceSession('yolopv2.onnx', providers=providers)
outputs = session.run(None, {'images': input_tensor})
det_boxes, drivable_mask, lane_lines = outputs[0], outputs[1], outputs[2]
3. Metric 2D Aerial Bird's-Eye View (BEV) Homography
Perspective foreshortening severely distorts distance estimation in raw camera frames. We compute an orthogonal Bird's-Eye View using calibrated homography matrix $M_{\text{bev}}$:
$$s \cdot \begin{bmatrix} u_{\text{bev}} \\ v_{\text{bev}} \\ 1 \end{bmatrix} = M_{\text{bev}} \begin{bmatrix} u_{\text{cam}} \\ v_{\text{cam}} \\ 1 \end{bmatrix}$$
In metric BEV space ($360 \times 720\,\text{px}$, where $1\,\text{px} \approx 0.08\,\text{m}$), the vehicle's hood is anchored at $(x = 198\,\text{px}, y = 640\,\text{px})$, providing calibrated $36\,\text{px}$ symmetric lateral clearance on either side of the vehicle body.
4. Curvature-Constrained Optimal Trajectory Planning
To eliminate high-frequency steering snap and actuator jerk, we designed a multi-tranche candidate optimization engine:
1.
Depth Tranche Discretization: The drivable corridor is sliced into $10\,\text{px}$ horizontal tranches up to a $50\,\text{m}$ lookahead horizon.
2.
Cost Function Optimization: Candidate lane centroids $x_k$ minimize:
$$J(x_k) = w_{\text{hist}} |x_k - x_{\text{prev}}| + w_{\text{ego}} |x_k - x_{\text{ego}}| + w_{\text{curv}} \kappa_k^2$$
3.
Curvature Clamping Optimizer: Limits geometric spline curvature:
$$|\kappa(y)| = \frac{|x''|}{(1 + (x')^2)^{1.5}} \le \kappa_{\max} = 0.003\,\text{px}^{-1} \implies R_{\min} \ge 28\,\text{m}$$
4.
Laplacian Smoothing: A 25-iteration relaxation pass with $\alpha = 0.40$ Exponential Moving Average guarantees continuous curvature derivatives ($C^2$ continuity) for steer-by-wire servos.